MS by Research, Robotics Research Center, IIIT Hyderabad
Amitabh Sharma
Adaptive and impedance control for aerial manipulators that have to interact with the world, with a particular interest in safety filters, payload-aware controllers, and proofs that can be machine-checked.
Featured work
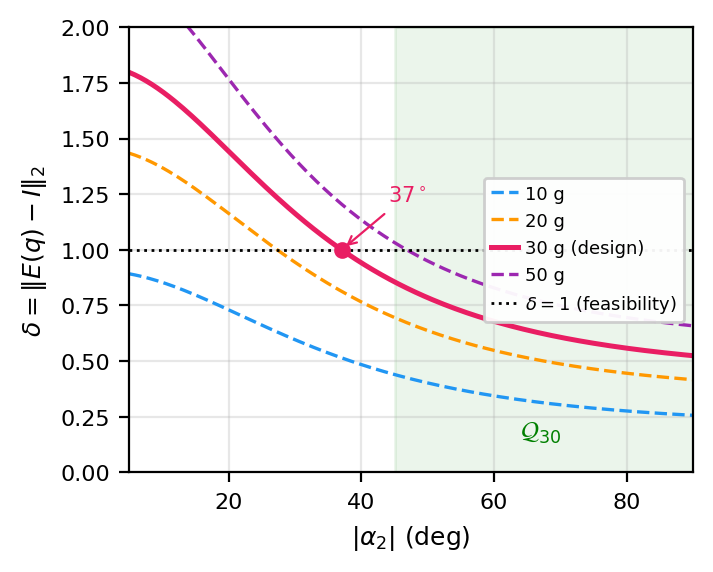
Payload Feasibility Certificate
A pre-flight test that asks whether an aerial manipulator can safely lift a given payload, with a closed-form bound and a Lean 4 proof script.
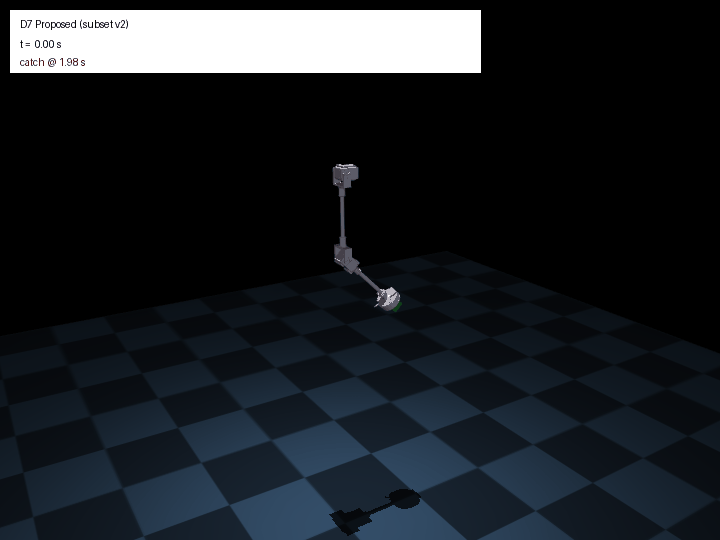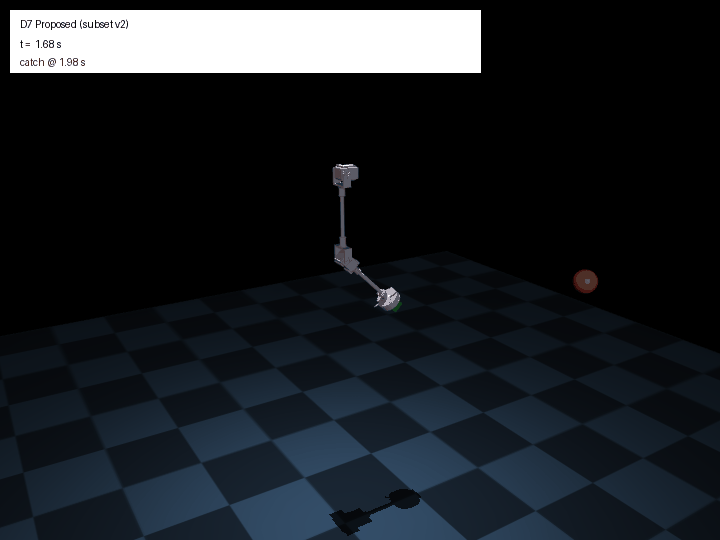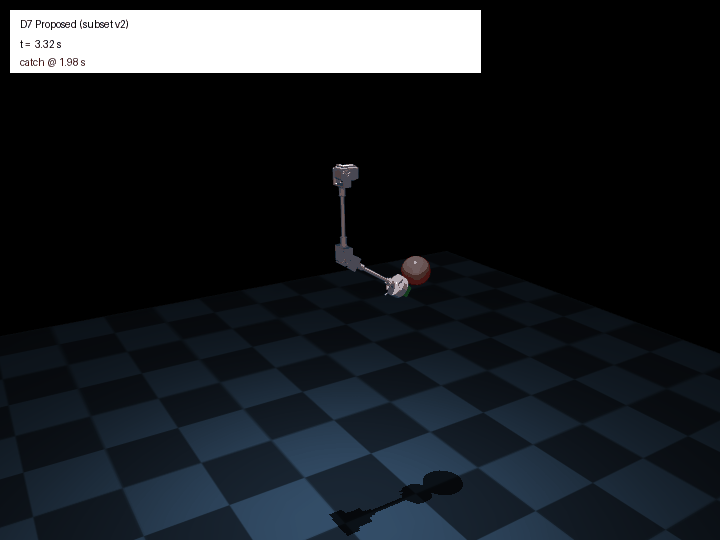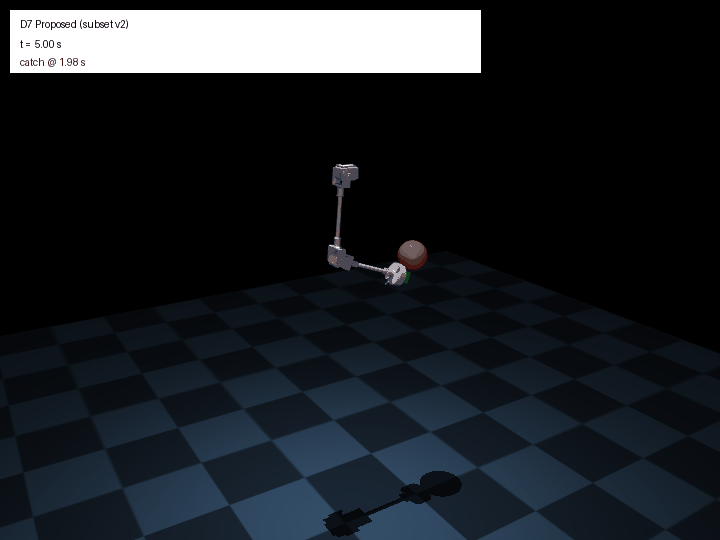
Adaptive Impedance for Aerial Catching
A 2R arm on a hovering quadrotor catches a thrown ball, estimating the payload mass on impact while keeping the wrench delivered back to the base under control.
Research interests
Adaptive impedance control
Compliant aerial manipulation under unknown vehicle–arm coupling. Stability via Lyapunov; experiments on real hardware.
Safety filters with certificates
Energy-based barrier functions paired with closed-form pre-flight bounds, plus Lean 4 verification of the load-bearing lemmas.
Fault-tolerant flight
Quadrotor control under partial actuator loss and state-dependent disturbances, with adaptive laws that survive the failure mode.
Want the long version?
Posts and notes on what I find interesting about controls, formal proofs, and where this work fits.