Sitemap
A list of all the posts and pages found on the site. For you robots out there, there is an XML version available for digesting as well.
Pages
MS-Research student in Robotics at IIIT Hyderabad. Adaptive and impedance control for aerial manipulation.
Posts
Coming across Lean: when a proof assistant turned into a research tool
Published:
I first heard about Lean the way most engineers do: as something mathematicians used to formalize the Liquid Tensor Experiment, or to mechanize a kilometre of group theory in mathlib4. It looked like a museum exhibit: beautiful, far away, and not for me.
Optimization-plus-modelling is the universal solvent
Published:
I came into research wanting to build flying robots. The arc I did not expect is how much of the math turned out to be useful far away from anything that flies. The longer I stare at a control problem, the more it looks like the inside of a delivery routing problem, or a recommendation feed, or a traffic light at a busy intersection. The accident of which domain it came from feels less important than the shared structure.
Two things aerial manipulation papers under-report: base forces and impedance error
Published:
If you read enough aerial manipulation papers, two omissions start to feel structural. The first is the wrench transmitted to the base of the quadrotor during contact. The second is the impedance-tracking error during the transient, not the steady-state error, but the few hundred milliseconds when the arm first touches the world. I want to argue, gently, that both of these deserve a row in every comparison table.
A small note on Lyapunov functions, my favourite idea in engineering
Published:
Engineers carry a small bag of ideas around with them that they trust more than anything else they were taught. Different engineers carry different bags. For me, near the top, is the Lyapunov function.
The honest cost of “we tuned the gains by hand”
Published:
A confession I would like to see in more controls papers: the gains were tuned by hand, on the test cases shown in the figure, by a person who was rooting for the controller.
portfolio
Adaptive Impedance Control with Payload-Mass Estimation for Aerial Catching
A 2R arm on a hovering quadrotor catches a thrown ball; the controller estimates the payload mass on impact while keeping the wrench delivered back to the base under control.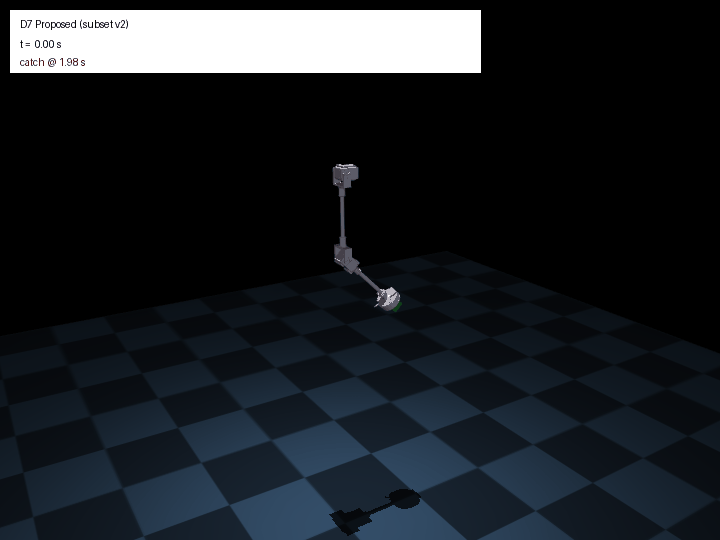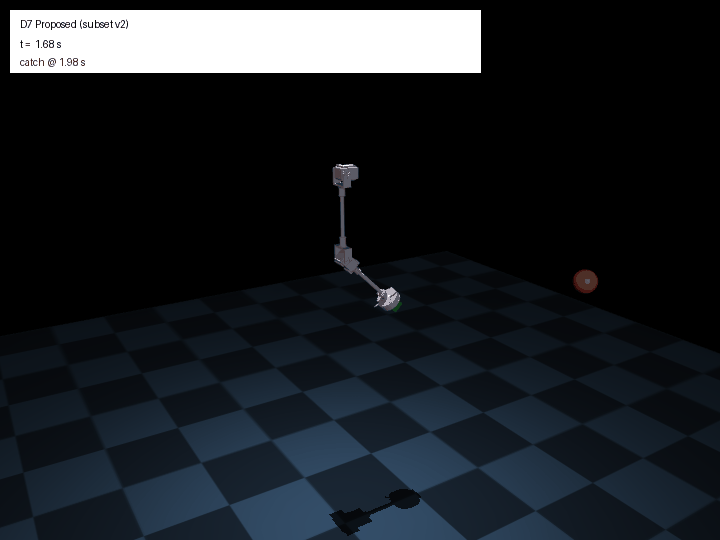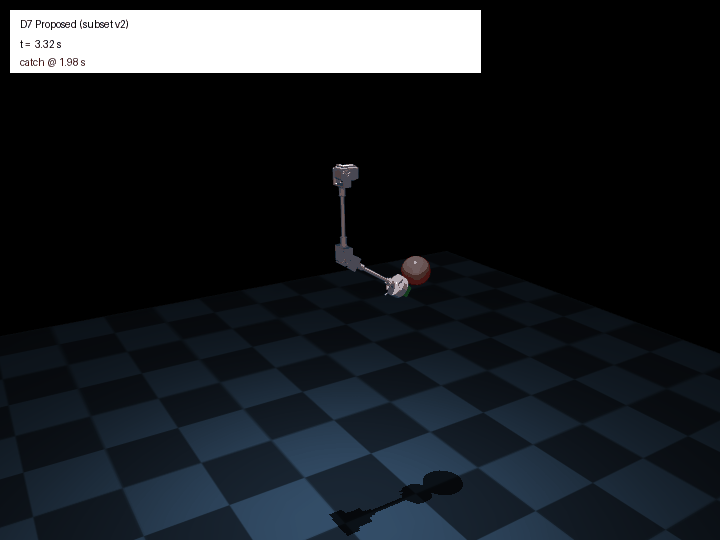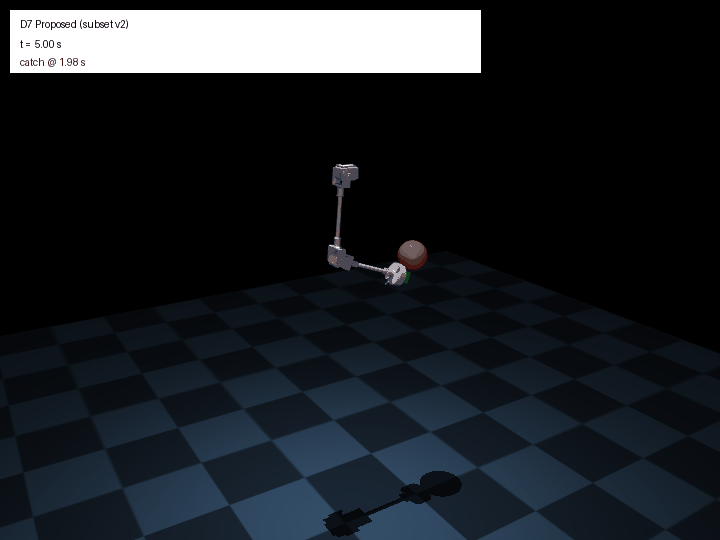
Payload Feasibility Certificate for Energy-Based Safety Filters
A pre-flight test that asks whether an aerial manipulator can safely lift a given payload, paired with a closed-form bound and a Lean 4 proof script.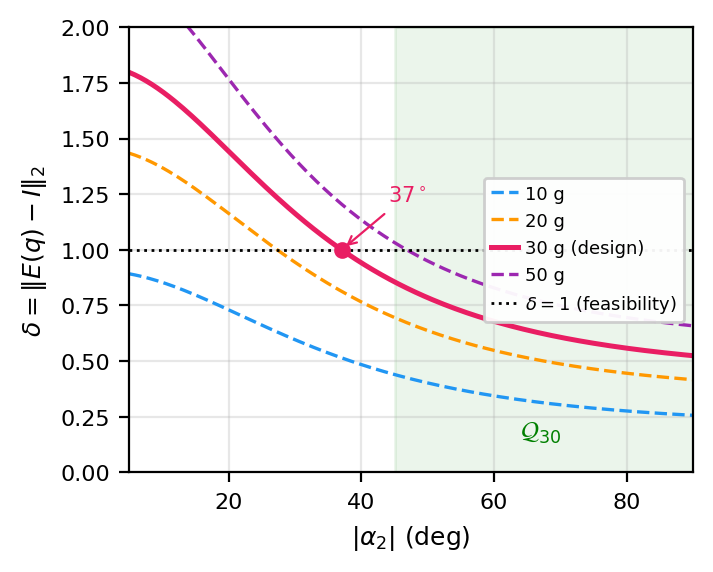
publications
Adaptive Control of Quadrotor under Actuator Loss and Unknown State-dependent Dynamics
Adaptive control framework for quadrotors handling actuator loss and unknown state-dependent dynamics.
Recommended citation: S. Gupta, A. Sharma, A. Mulgundkar, R.D. Yadav, S. Roy (2024). "Adaptive Control of Quadrotor under Actuator Loss and Unknown State-dependent Dynamics." In IEEE CASE 2024. doi:10.1109/CASE59546.2024.10711418.
Download Paper
Impedance and Stability Targeted Adaptation for Aerial Manipulator with Unknown Coupling Dynamics
Conference paper (in press) on adaptation targeting impedance and stability for aerial manipulators with unknown coupling dynamics.
Recommended citation: A. Sharma, S. Gupta, S. Singh, R.D. Yadav, H. Song, W. Pan, S. Roy, S. Baldi (2025). "Impedance and Stability Targeted Adaptation for Aerial Manipulator with Unknown Coupling Dynamics." In Proceedings of ICCAS 2025.
Download Paper
An integrated approach to aerial grasping: Combining a bistable gripper with adaptive control
Journal article on combining a bistable gripper with adaptive control for robust aerial grasping.
Recommended citation: R.D. Yadav, B. Jones, S. Gupta, A. Sharma, J. Sun, J. Zhao, S. Roy (2025). "An integrated approach to aerial grasping: Combining a bistable gripper with adaptive control." IEEE/ASME Transactions on Mechatronics. doi:10.1109/TMECH.2025.3586888.
Download Paper
teaching
Teaching Assistant, Robotics: Dynamics and Control
Drafted and graded assignments, quizzes, projects, and exam papers; conducted weekly doubt-clearing sessions.
Teaching Assistant, Mechatronics System Design
Drafted and graded assignments, quizzes, projects, and exam papers; conducted weekly doubt-clearing sessions.